Compare Vision Assisted Travel Options: The Definitive Guide to Autonomous Transit
The global infrastructure for transit is fundamentally biased toward visual processing. From the high-contrast typography of airport signage to the color-coded intricacies of metropolitan rail maps, the world is a tapestry of optical cues. For individuals with visual impairments, navigating this environment requires more than just a peripheral aid; it demands a sophisticated integration of sensory substitution, technological overlays, and human-centric systems. As we move deeper into the mid-2020s, the traditional boundaries between “low-tech” white canes and “high-tech” spatial computing are blurring, creating a hybrid landscape of mobility.
This evolution is not merely a technological triumph but a shift in the philosophy of autonomy. In the past, vision-assisted travel was often viewed through the lens of protectionism, keeping the traveler safe from the environment. Modern frameworks, however, focus on “Environmental Interpretation,” empowering the individual to perceive the nuances of their surroundings with the same fidelity as a sighted peer. This involves a complex interplay of haptic feedback, bone-conduction audio, and real-time data streaming that transforms a silent, invisible street corner into a rich, informative data node.
To effectively evaluate the current landscape, one must look beyond the individual tools and examine the “Systemic Reliability” of each approach. A traveler navigating an unfamiliar city is not just using a device; they are engaging with a multi-layered support network. This article provides a comprehensive editorial baseline for stakeholders, families, and travelers themselves to analyze the efficacy, cost-benefit ratios, and psychological impacts of modern navigation strategies. By deconstructing these layers, we can move away from superficial comparisons and toward a deep, functional understanding of sight-free mobility.
Understanding “compare vision-assisted travel options.”
When stakeholders begin to compare vision-assisted travel options, they frequently fall into the trap of looking for a “silver bullet”—a single device that solves all navigational challenges. In reality, the “best” option is rarely a single tool but rather a “Tactical Stack” of overlapping systems. A traveler might use a white cane for tactile feedback of immediate ground-level obstacles, while simultaneously utilizing a wearable AI camera for long-range object recognition and a GPS-based audio beacon for city-scale orientation.
The primary misunderstanding in this sector is the conflation of “Obstacle Detection” with “Wayfinding.” These are two distinct cognitive tasks. Obstacle detection is the reactive process of avoiding immediate hazards, whereas wayfinding is the proactive process of maintaining a mental map and navigating toward a destination. An option that excels at one may be entirely deficient in the other. For instance, a basic ultrasonic sensor can warn of a low-hanging branch but offers zero assistance in locating the correct subway entrance on a crowded plaza.
Oversimplification also leads to a neglect of the “User-Environment Interface.” A travel plan that works perfectly in a grid-based North American city may collapse in the medieval, winding streets of a European capital or the high-density sensory chaos of a Southeast Asian market. A robust comparison must therefore account for “Contextual Resilience,” the ability of a mobility system to remain functional when digital signals drop or environmental noise reaches peak levels.
Deep Contextual Background: The Evolution of Sight-Free Movement
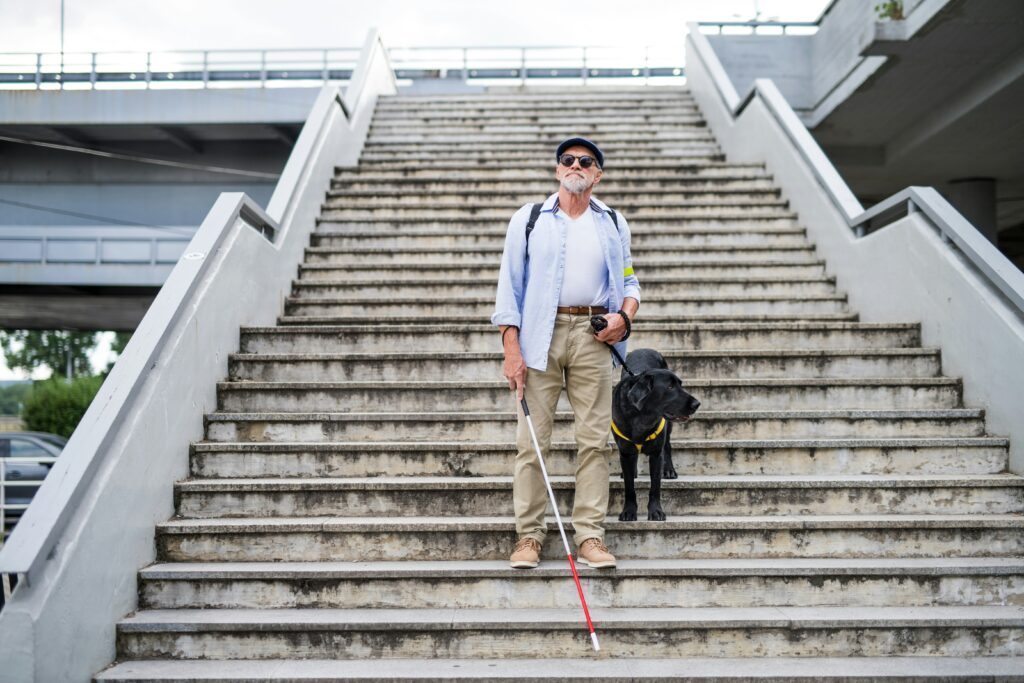
The history of vision assistance is a transition from “Internalized Skill” to “Externalized Intelligence.” For decades, the gold standard was O&M (Orientation and Mobility) training focused on the white cane and the guide dog. These are “Kinetic Mastery” models, relying on the user’s ability to interpret subtle physical vibrations or the non-verbal cues of a highly trained animal.
By the late 2010s, the “Digital Augmentation” era arrived. This was characterized by the first generation of smartphone apps that could identify currency or read labels. However, these were tethered, slow, and often required a high cognitive load to operate while moving. By 2026, we will have transitioned into the “Spatial Intelligence” era. Today’s systems leverage Computer Vision (CV) and Edge Computing to provide instantaneous, heads-up feedback. The infrastructure has moved from the user’s pocket to the cloud, where real-time human-in-the-loop assistance (remote agents) can “see” through a traveler’s glasses, providing a level of nuance that algorithms still struggle to replicate.
Conceptual Frameworks and Mental Models
To evaluate navigation systems with editorial rigor, consider these frameworks:
1. The “Sensory Budget” Model
Every person has a finite amount of cognitive energy. If a mobility tool requires 80% of a traveler’s attention to operate, they have only 20% left to enjoy their surroundings or manage social interactions. High-performing options are those that minimize “Sensory Overhead.”
2. The “Active vs. Passive” Information Loop
A “Passive” tool waits for the user to query it (e.g., “Where am I?”). An “Active” tool provides proactive data (e.g., “Note: The sidewalk is narrowing in 10 feet”). The goal is a balance that avoids “Information Flooding” while preventing “Environmental Blind Spots.”
3. The “Reliability of Handover” Logic
This assesses what happens when a system fails. If a GPS signal is lost in a tunnel, does the tool provide “Inertial Dead Reckoning,” or does it simply stop working? A system’s value is defined by its “Graceful Degradation”—how well it supports the user during a partial failure.
Key Categories and Strategic Trade-offs
The current market is divided by the “Primary Input Mode.”
| Category | Primary Mechanism | Core Advantage | Strategic Trade-off |
| Tactical Kinetic | White Cane | 100% Reliability; no batteries | Zero long-range detection |
| Biological Partnership | Guide Dog | Complex decision-making; companion | High cost; maintenance/care needs |
| Wearable Computer Vision | Smart Glasses (AI) | Hands-free; object recognition | Battery dependency; privacy concerns |
| Remote Human Support | Live Video Agents | High nuance; social interpretation | Subscription cost, internet-dependent |
| Haptic Feedback Arrays | Vibrating Belts/Inserts | Silent; intuitive directionality | Limited information density |
| Audio-Beacon GPS | Spatialized Audio | Excellent wayfinding | Masks environmental audio cues |
Decision Logic: The “Acuity vs. Environment” Curve
When individuals compare vision-assisted travel options, the “Pivot Point” is often the density of the environment. In a quiet suburb, a white cane and a simple GPS app are often sufficient. In a “Dense Urban Node,” the traveler likely needs a combination of remote human assistance for signage and haptic feedback to navigate the “Dynamic Hazards” of moving traffic and construction.
Detailed Real-World Scenarios
The Multi-Modal Transit Transfer
-
The Context: Navigating a three-level train station with ongoing construction.
-
The Challenge: Standard GPS is non-functional indoors; floor tactile markings are obscured by plywood barriers.
-
The Failure Mode: Relying on automated AI, which confuses the sound of construction with a moving train.
-
The Systemic Solution: A remote human agent who can read temporary paper signs and direct the traveler to the specific elevator bay.
The “Quiet Street” Crossing
-
The Context: An intersection with “Quiet” electric vehicles (EVs).
-
The Risk: Traditional auditory “listening for traffic” is less reliable as EV adoption increases.
-
The Nuance: The travel plan incorporates “V2X” (Vehicle-to-Everything) alerts sent to the traveler’s wearable device when an EV is approaching the crosswalk.
Planning, Cost, and Resource Dynamics
The economic landscape of vision assistance is bifurcated between “One-Time Capital Expenditures” and “Ongoing Operational Expenses.”
Range-Based Cost Analysis (2026 Projections)
| Expense Type | Low-End (Essential) | High-End (Integrated) | Variability Factors |
| Primary Tool | $50 (Pro Cane) | $3,500 (AI Glasses) | Brand; sensor sophistication |
| Service Subscriptions | $0 (Self-Reliant) | $150 – $300 / mo | Usage hours for remote agents |
| Training (O&M) | $0 (Public/Gov) | $5,000+ (Private) | Complexity of travel goals |
| Equipment Maintenance | $20 / yr | $400 / yr | Battery health; data plans |
The “Opportunity Cost” of Dependency: A high hidden cost is the “Time Tax.” A traveler using a low-fidelity system may spend 30% more time on every trip due to “Check-and-Verify” stops. Over a year, this represents a massive drain on productivity. Therefore, a more expensive system that provides higher “Transit Velocity” often has a superior ROI.
Tools, Strategies, and Support Systems
-
Spatialized Audio Maps: Utilizing bone-conduction headphones to place virtual “pins” in the air, allowing the user to “hear” where the coffee shop is located relative to their body.
-
Ultra-Wideband (UWB) Indoor Positioning: Providing centimeter-level accuracy inside malls and hospitals where GPS fails.
-
Collaborative Mapping: Platforms where users can tag “Micro-Hazards” (e.g., a broken curb or a poorly placed scooter) in real-time for other travelers.
-
Remote Visual Scribes: Professional agents who can assist with reading menus, identifying seat numbers, or locating specific items on a grocery shelf.
-
Smart Cane Attachments: Adding ultrasonic sensors to standard canes to provide haptic vibration in the handle when head-height obstacles are detected.
-
Tactile Digital Displays: Portable tablets that can “render” a map of a room in raised dots, providing a quick mental overview of a space before entering.
Risk Landscape and Failure Modes
The Taxonomy of Navigational Fragility
-
Digital Enclosure: The risk of becoming “stranded” if a smartphone battery dies or a cellular network goes down in a rural area.
-
Signal Masking: Excessive audio feedback that prevents the traveler from hearing a bicycle bell or an approaching siren.
-
Over-Confidence Bias: A phenomenon where a traveler trusts an AI’s “Safe to Cross” signal without verifying the physical environment, leading to a “Second-Order Accident.”
-
Environmental Masking: Heavy rain or snow that “blinds” ultrasonic sensors or muddies the tactile feedback of a cane on a sidewalk.
Governance, Maintenance, and Long-Term Adaptation
A mobility plan is a “Living Document” that must be audited as technology and physiology change.
The “Adaptive Mobility” Checklist
-
Software Governance: Ensuring that “Auto-Updates” are turned off during travel to prevent a firmware glitch from disabling a device in a foreign city.
-
Hardware Redundancy: Always carrying a “Mechanical Baseline” (the white cane) regardless of how advanced the digital tools are.
-
Physiological Review: Adjusting plans as hearing acuity or physical stamina changes over time.
-
Trigger Events: Establishing “Safe Zones” where the traveler can stop and reset their equipment if they feel disoriented or overwhelmed.
Measurement, Tracking, and Evaluation
-
Leading Indicator: “Confidence Delta.” Measuring the traveler’s heart rate or stress levels before and during a trip with a new device.
-
Lagging Indicator: “Arrival Variance.” Tracking the difference between the “Estimated Time of Arrival” and actual arrival over 20 trips.
-
Documentation Example: Maintaining a “Hazard Log” of locations where specific tools consistently failed, allowing for better “Routing Logic” in the future.
Common Misconceptions and Oversimplifications
-
Myth: “GPS is enough for solo travel.”
Correction: GPS tells you where you are, but not what is in your way. It is a macro-tool, not a micro-tool. -
Myth: “AI has made guide dogs obsolete.”
Correction: AI cannot yet match the “Situational Disobedience” of a dog the ability to refuse a command if it perceives a hidden danger. -
Myth: “Vibration feedback is annoying.”
Correction: For many, haptic feedback is the “Cleanest” data stream because it doesn’t interfere with auditory or social processing. -
Myth: “Public transit is always the best option.”
Correction: In many regions, ride-sharing with a remote human agent is safer and more efficient than navigating an inaccessible bus network.
Conclusion
The task to compare vision-assisted travel options is a journey into the heart of human resilience. We are moving away from a world of “Assistance” toward a world of “Seamless Integration.” The most successful travelers in 2026 are those who view their tools not as external gadgets, but as “Perceptual Extensions.” As spatial computing and sensor miniaturization continue to advance, the “Sight Gap” will continue to narrow. However, the ultimate success of these systems relies not on the complexity of the code, but on the intellectual honesty of the traveler knowing when to trust the technology, and when to trust the “Kinetic Wisdom” of the body.